About Me
I am a sophomore undergraduate student at IIIS (Yao Class), Tsinghua University, majoring in Computer Science (Artificial Intelligence Track).
Currently, I am a research assistant at the MARS Lab at the Institute for Interdisciplinary Information Sciences (IIIS), advised by Prof. Hang Zhao. My research interests lie in robot learning, with a focus on generative motion models and humanoid perceptive locomotion.
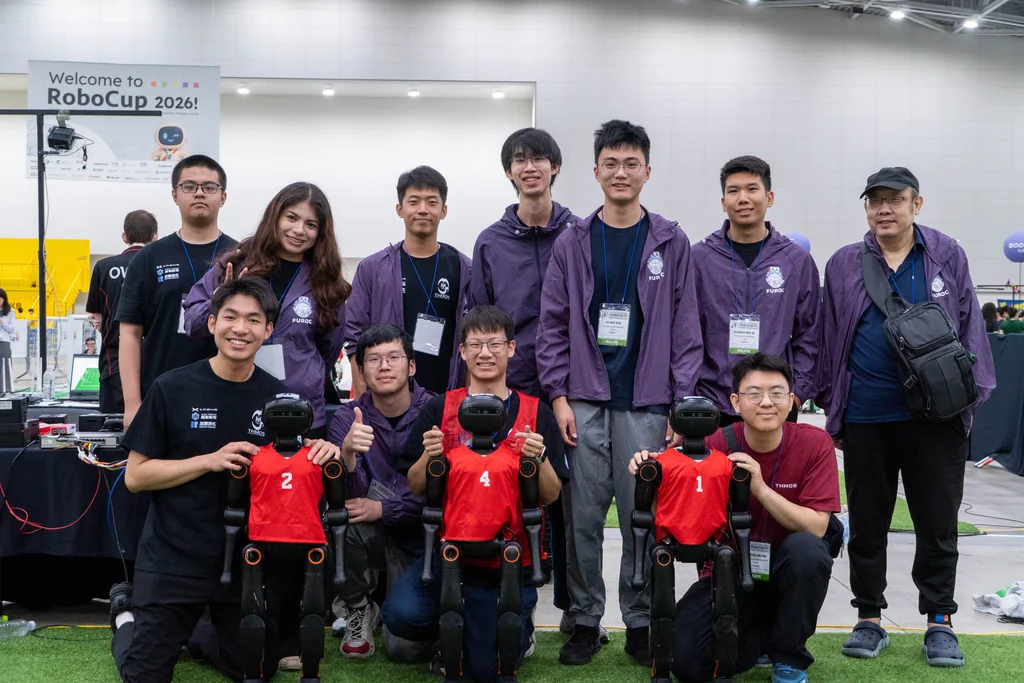
Additionally, I serve as the Technical Leader at TH-MOS (Tsinghua Master of Soccer), leading gait control and decision-making algorithm development for humanoid robot soccer.
I’m originally from Taoyuan, Taiwan, and grew up in Suzhou, Jiangsu. Outside of research, I enjoy playing the piano and am a member of the Tsinghua University Clavier Team. I also sing bass in the Yongheng Choir and enjoy playing frisbee.
News
- 🎓 I received the Comprehensive Excellence Award and the Scientific and Technological Innovation Award from Tsinghua University.
- 🎓 I received the Ministry of Education Scholarship for Taiwan Students (First Prize, Top 2 Schoolwide).
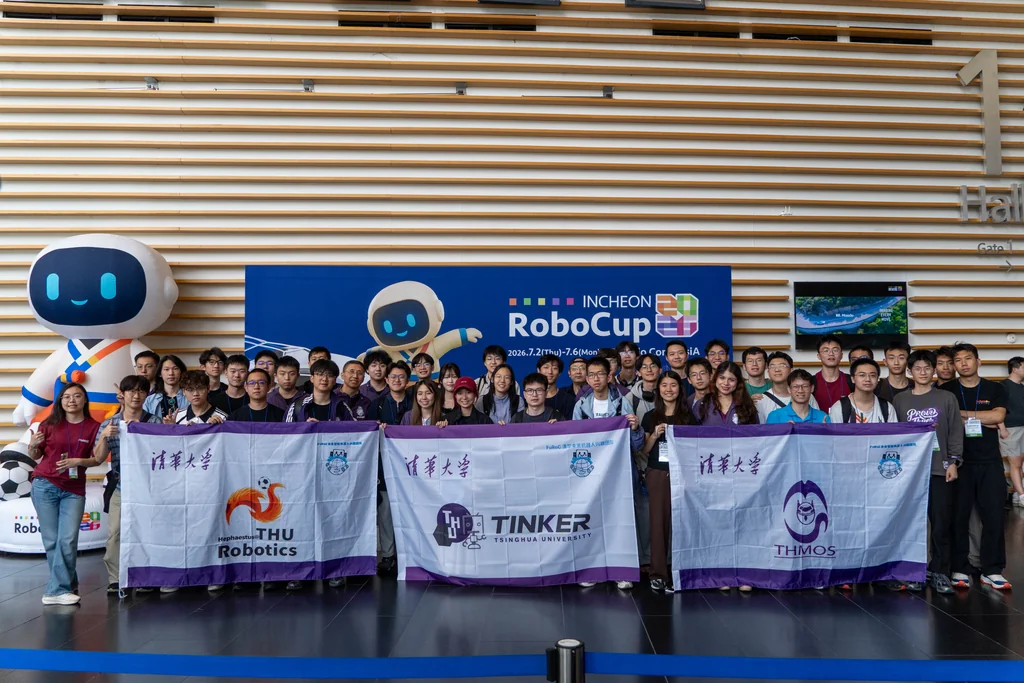
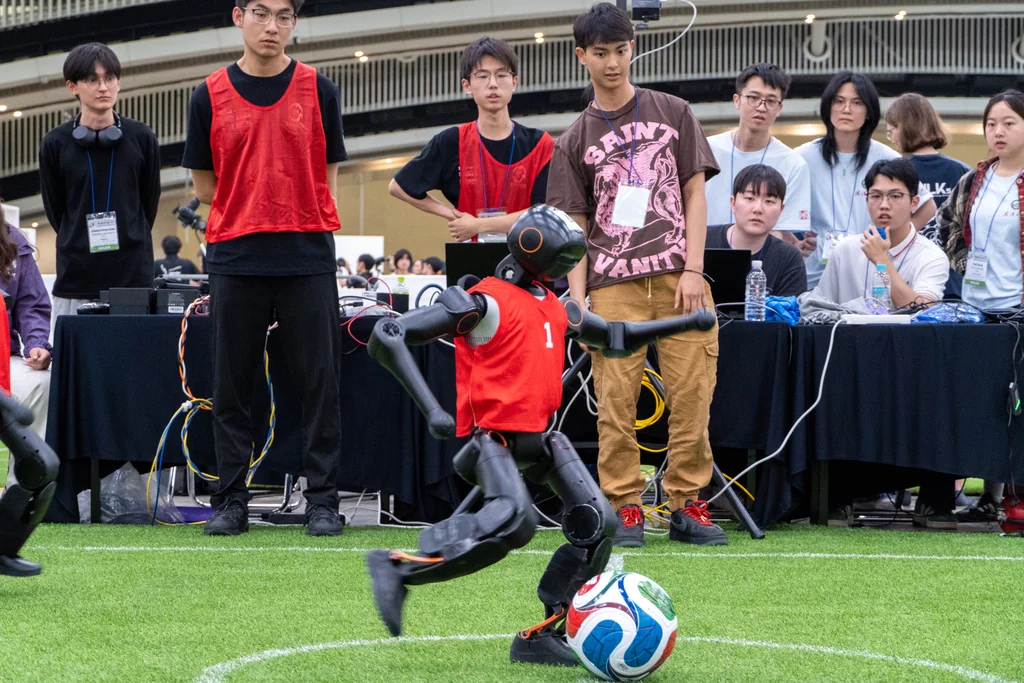
- 🏆 THMOS won 5th place in 2026 RoboCup (Incheon)!
- 🚀 OMG is released!
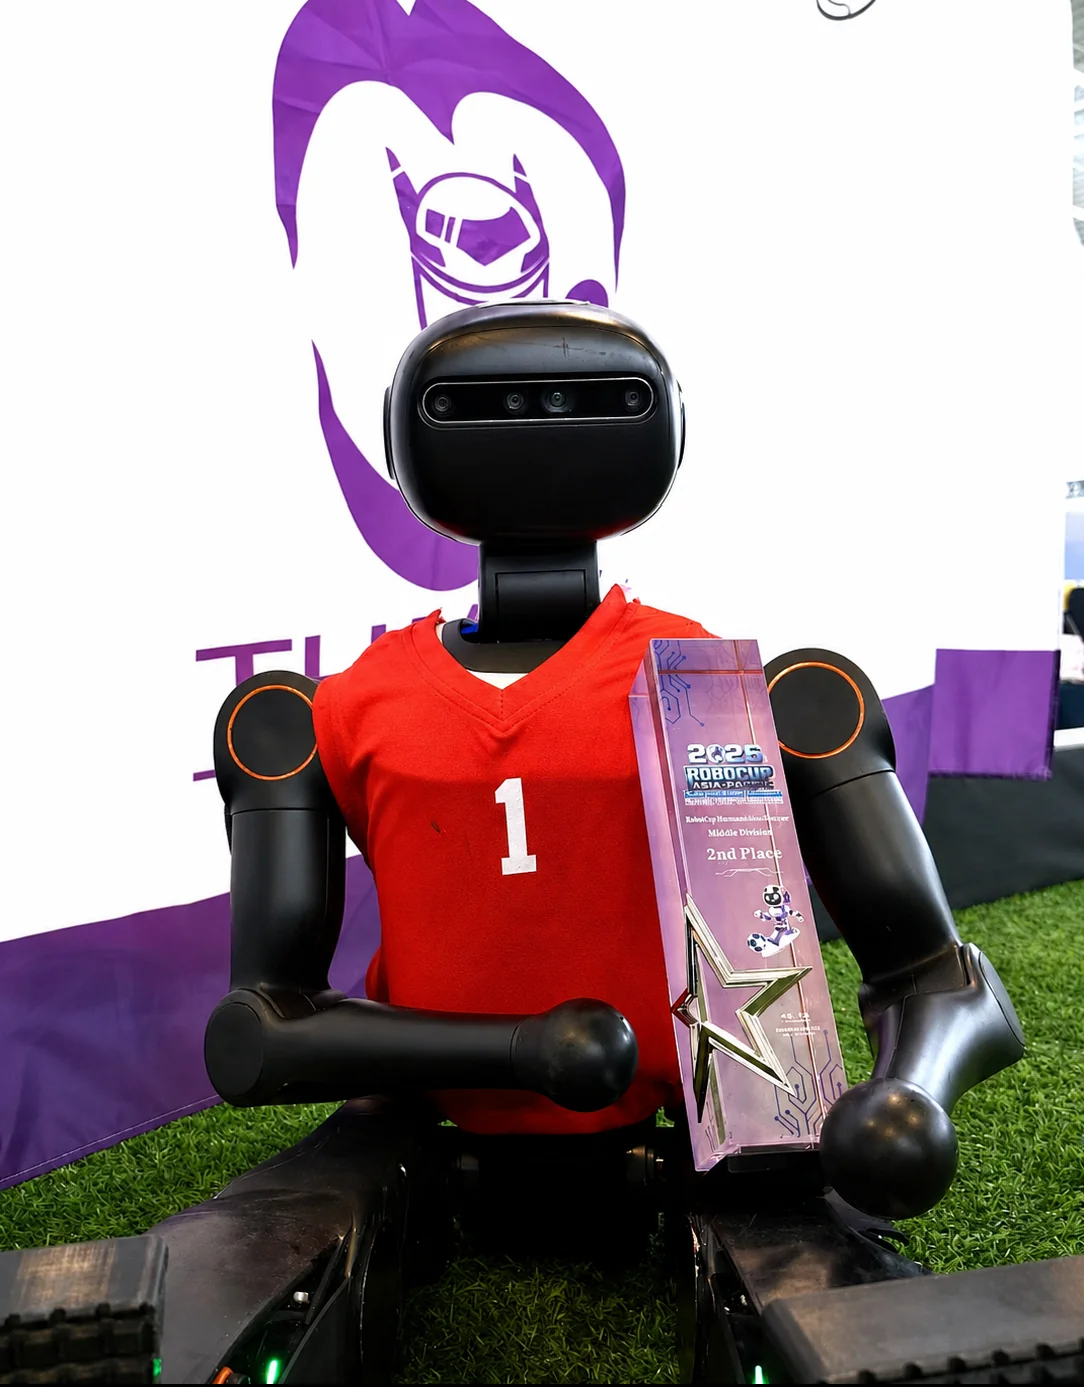
- 🥈 THMOS won 2nd Place in 2026 RoboCup Asia-Pacific (RCAP) Tianjin Invitational Tournament!
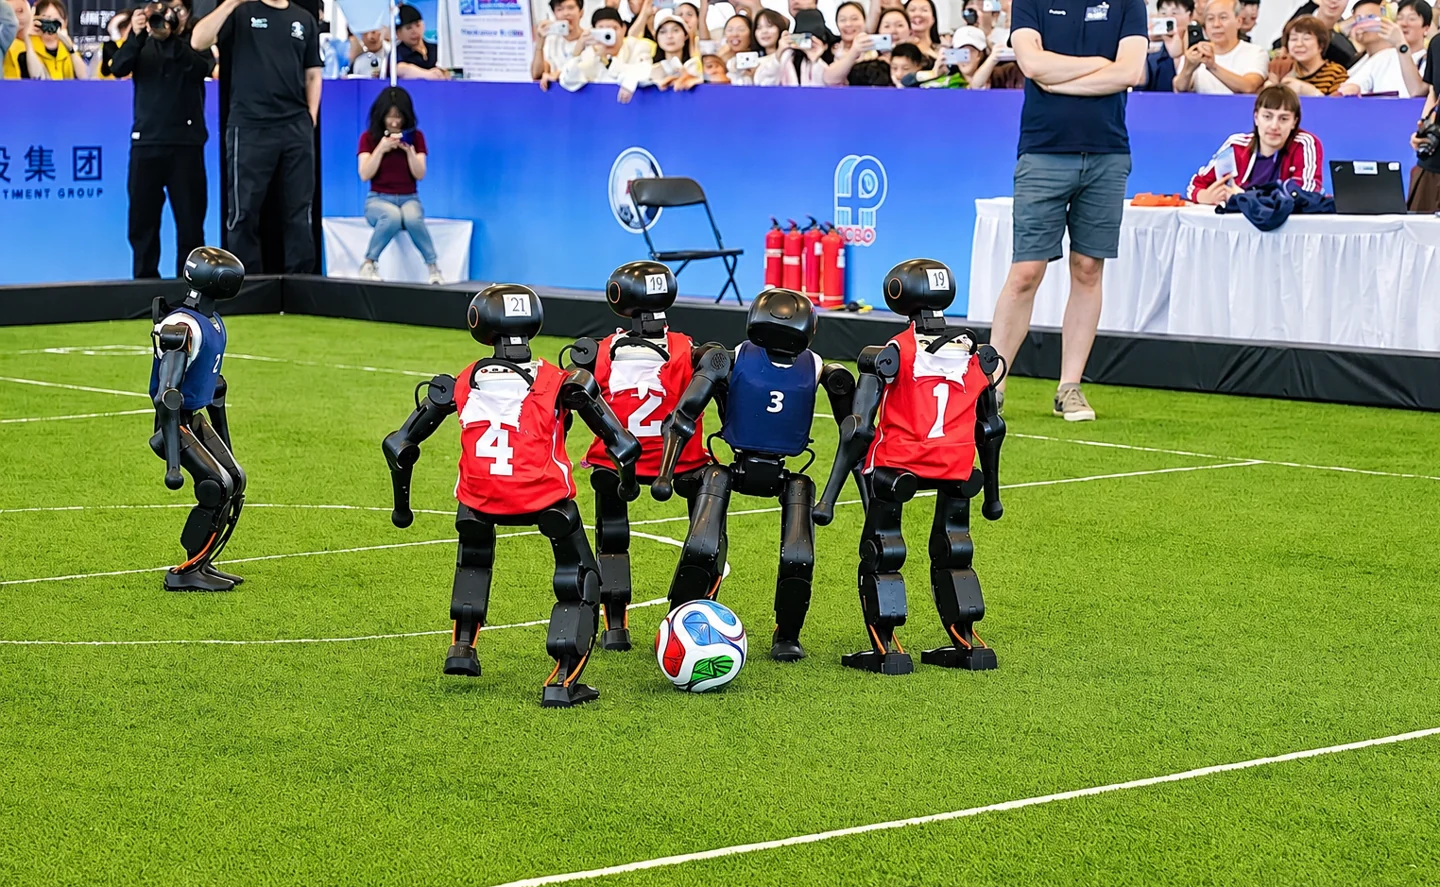
- 🥉 THMOS won 3rd Place in RoboCup China Open 2026!
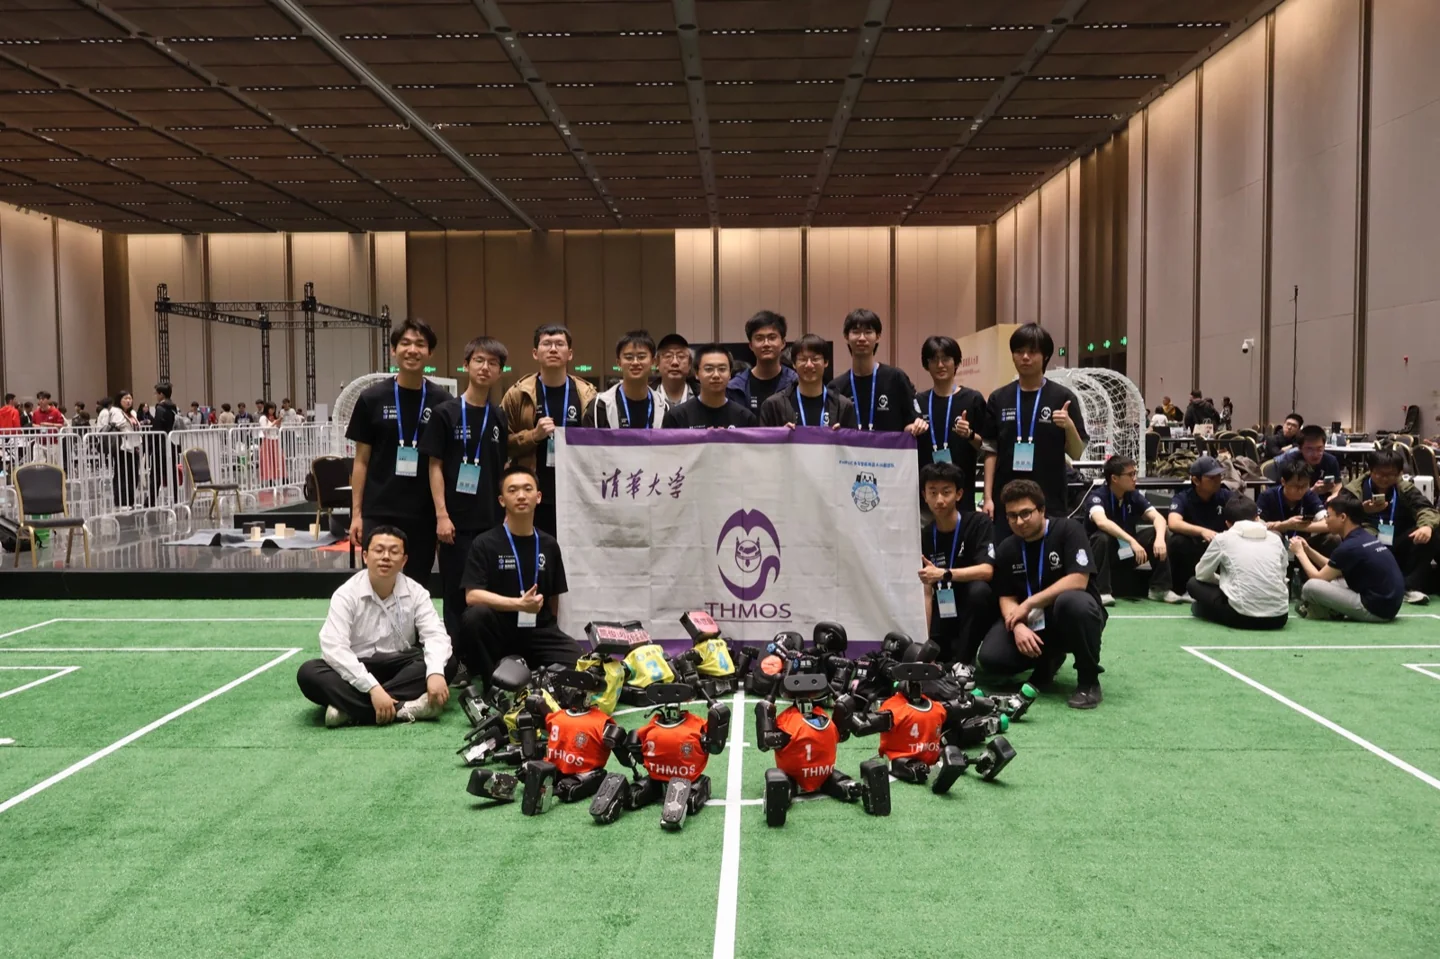
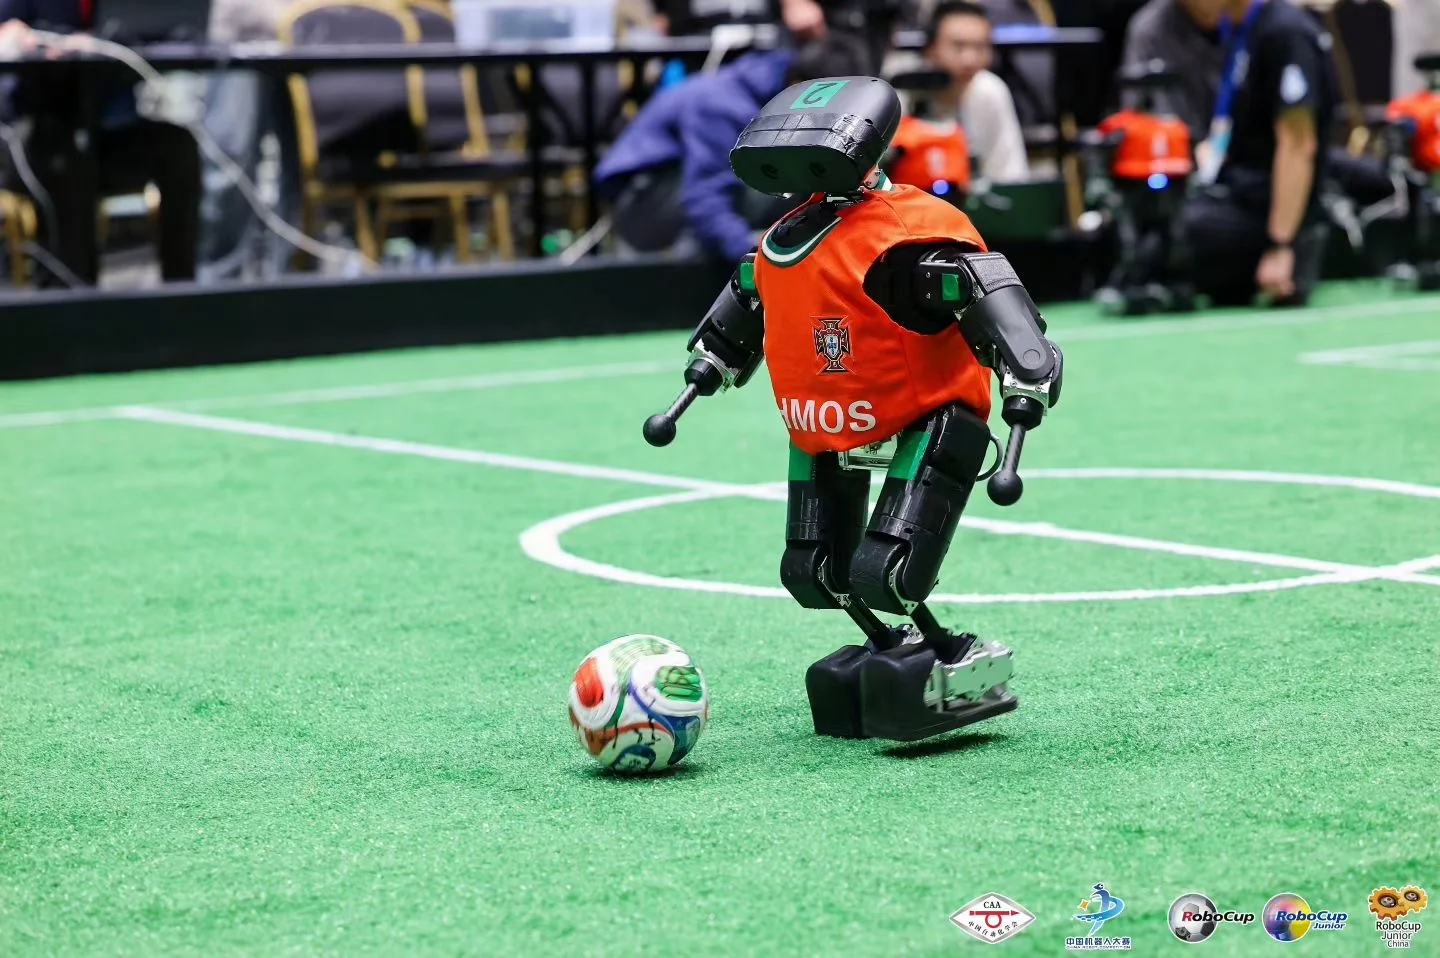
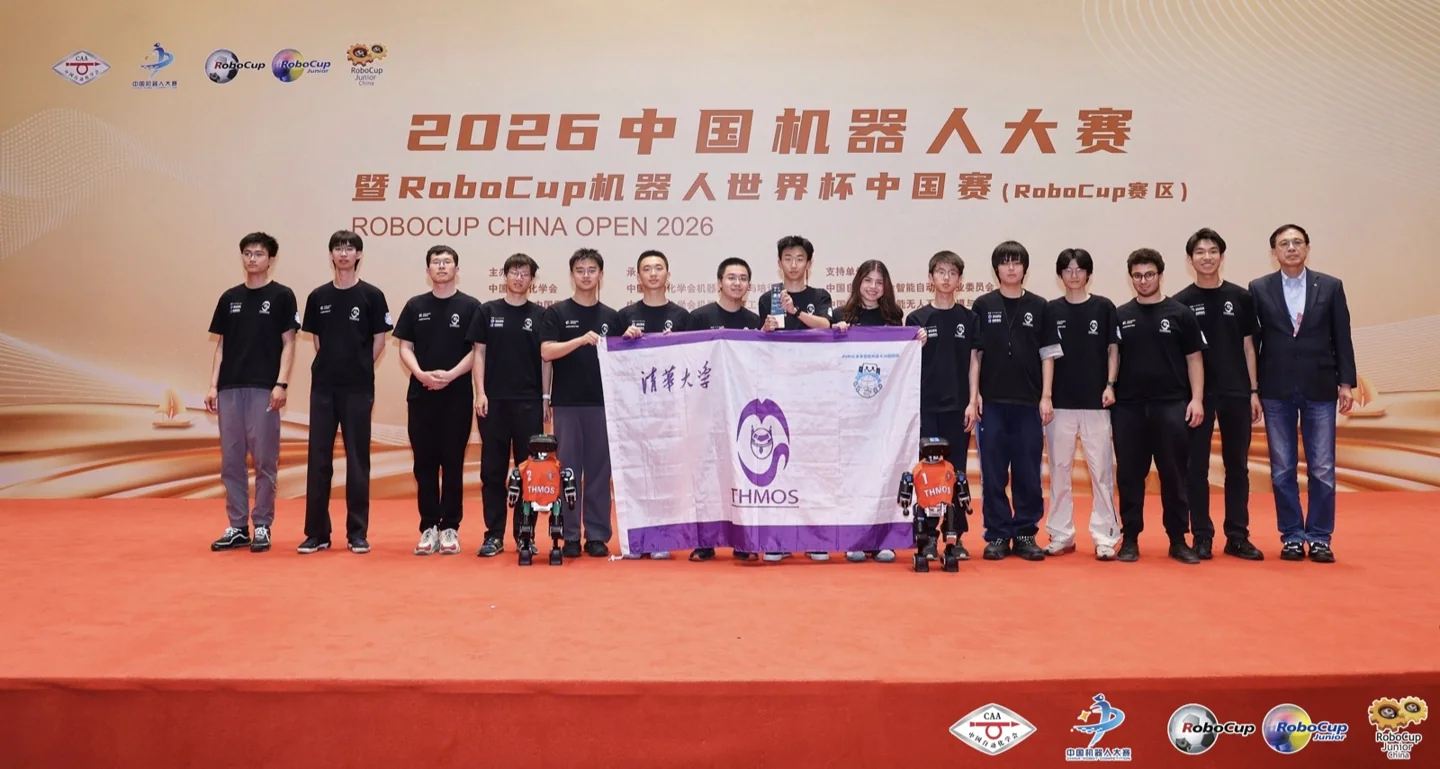
- 🤖 Joined TH-MOS Robot Soccer Team.

Publications
- ArXivArXiv Preprint, 2026ExWBC @ RSS 2026 Oral, RoboData @ RSS 2026 Spotlight
-
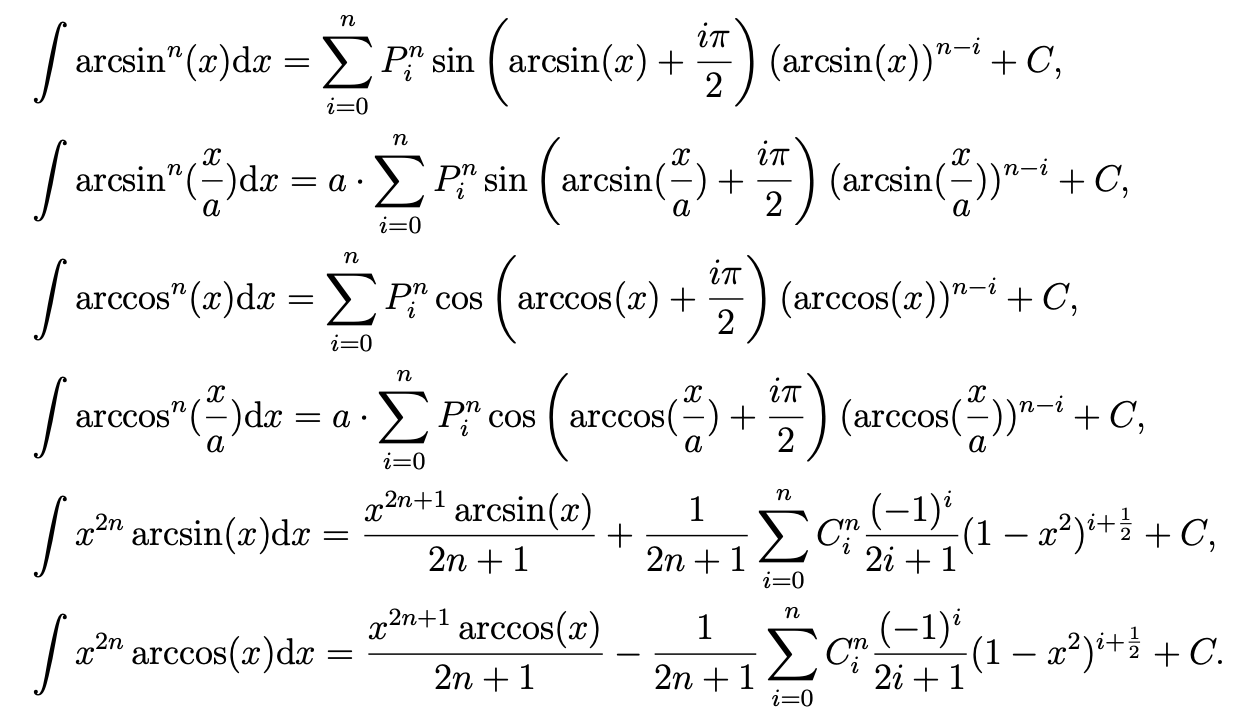 Mathmedia, Vol. 49, No. 2, 2025
-
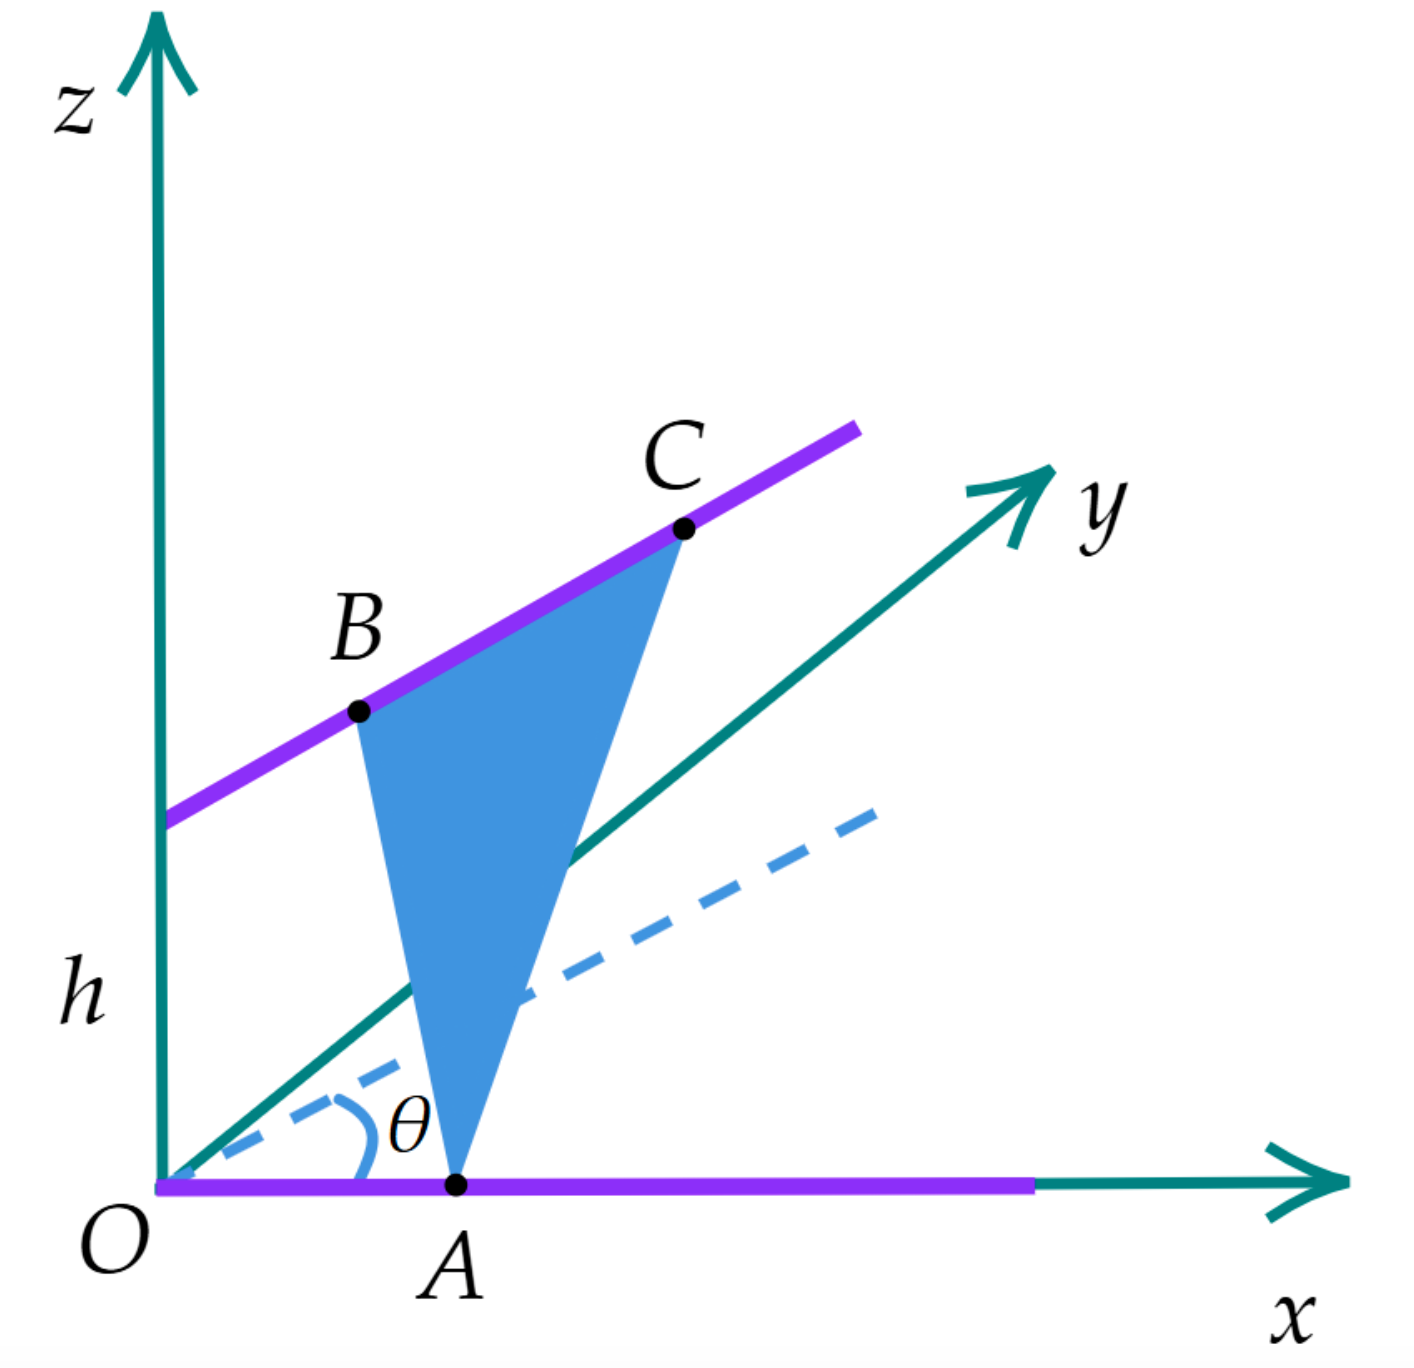 64th National Science Fair, Tainan City, Taiwan, Aug 2024
* Equal Contribution, † Corresponding Author
Projects
ScaleBFM-K1: Large-Scale Humanoid Motion Tracking
Adapted BFM-style motion tracking to the 22-DoF Booster K1, achieving over 95% full-clip completion on the BONES-SEED test set after 5 hours of training on a single node with 8 NVIDIA A10 GPUs. Deployed and verified the policy on the real robot.
SuperMimic on mjlab: Model-Based Humanoid Motion Tracking
Reproduced SuperMimic’s differentiable-world-model approach to humanoid motion tracking on native MuJoCo-Warp through mjlab, achieving 100% full-clip completion across 40 LAFAN1 motions within 5 hours of training on a single RTX 5090. Demonstrated few-shot adaptation to highly dynamic MotionCode motions.
Omnidirectional Locomotion
Developed command-conditioned AMP policies for omnidirectional locomotion on Booster K1, achieving stable real-robot velocity tracking from −1.5 to +2.0 m/s forward/backward, ±1.5 m/s laterally, and ±1.7 rad/s in yaw.
Fall Recovery
Trained an AMP-based fall-recovery policy in MJLab for Booster K1, recovering from tested fallen poses to stable standing within 0.5 s and succeeding in all 30 real-robot trials.
Dribbling
Trained reference-free dribbling on Booster K1 using asymmetric PPO, jointly learning locomotion and head control from ball-velocity commands, proprioception, and camera-frame ball observations.
Shooting
Developed target-conditioned shooting policies on Booster K1 to aim at specified 3D goal-mouth coordinates from positions across a 14 × 9 m field. Real-robot tests achieved targeting errors within 10 cm in 27 of 30 trials; demonstrations include a goal scored at RoboCup.
Built a Unity–MuJoCo platform for autonomous 3v3, 5v5, and 11v11 humanoid soccer, connecting learned locomotion, kicking, and recovery with perception, team decisions, and match management.
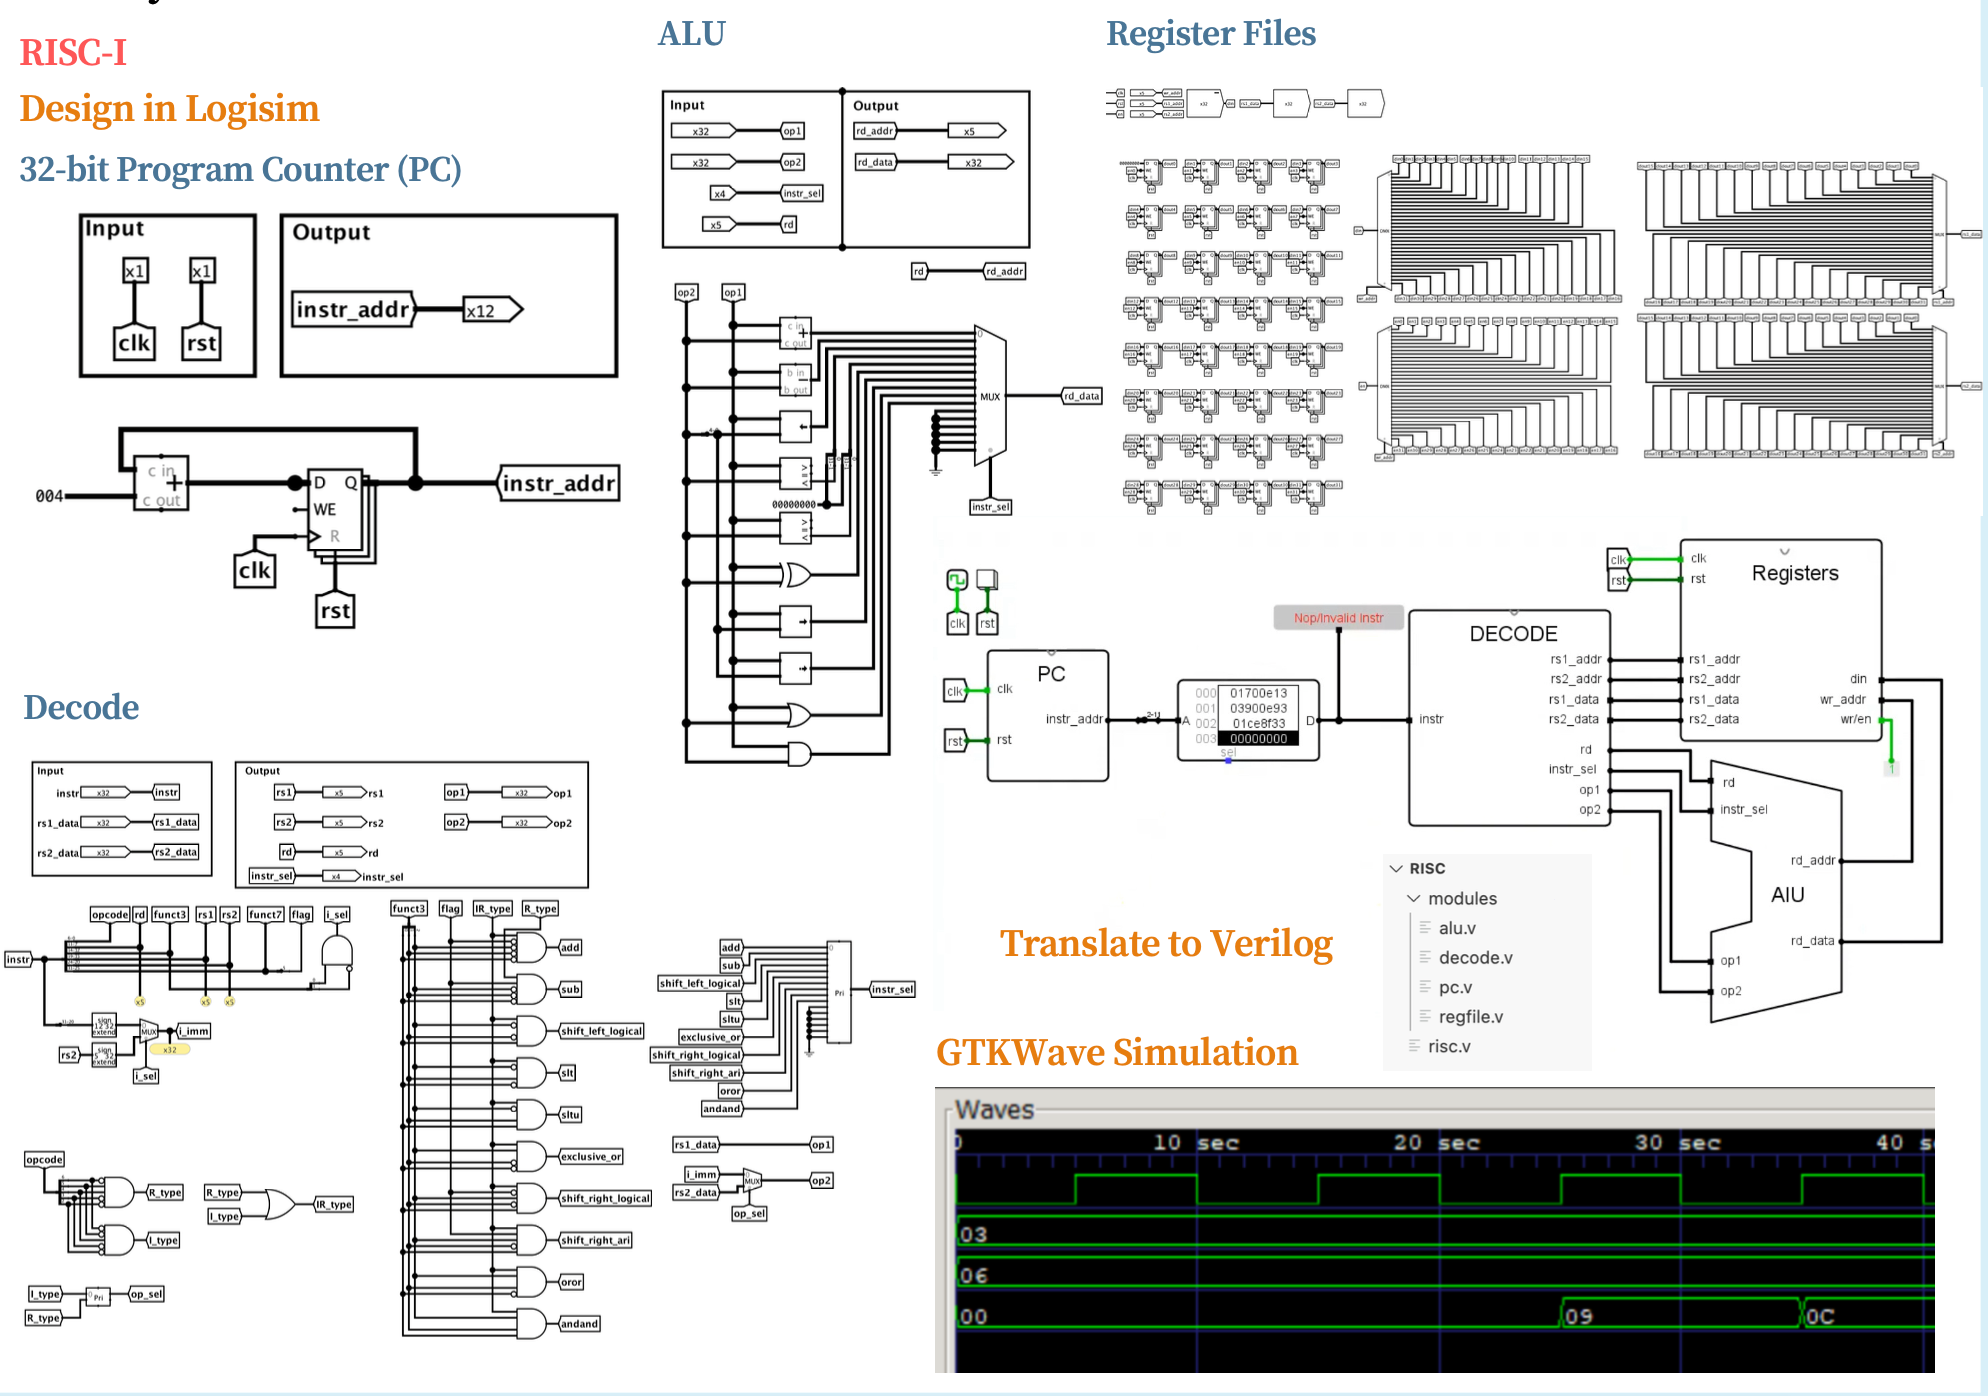
Logisim Based RISC CPU Implementation (Jun. 2025)
- Designed a 32-bit single-cycle RISC CPU using Logisim Evolution.
- Implemented modular components including ALU, Instruction Decoder, Program Counter, and Register File.
- Supported R-type (Arithmetic/Logical) and I-type (Immediate/Load/Control) instructions.
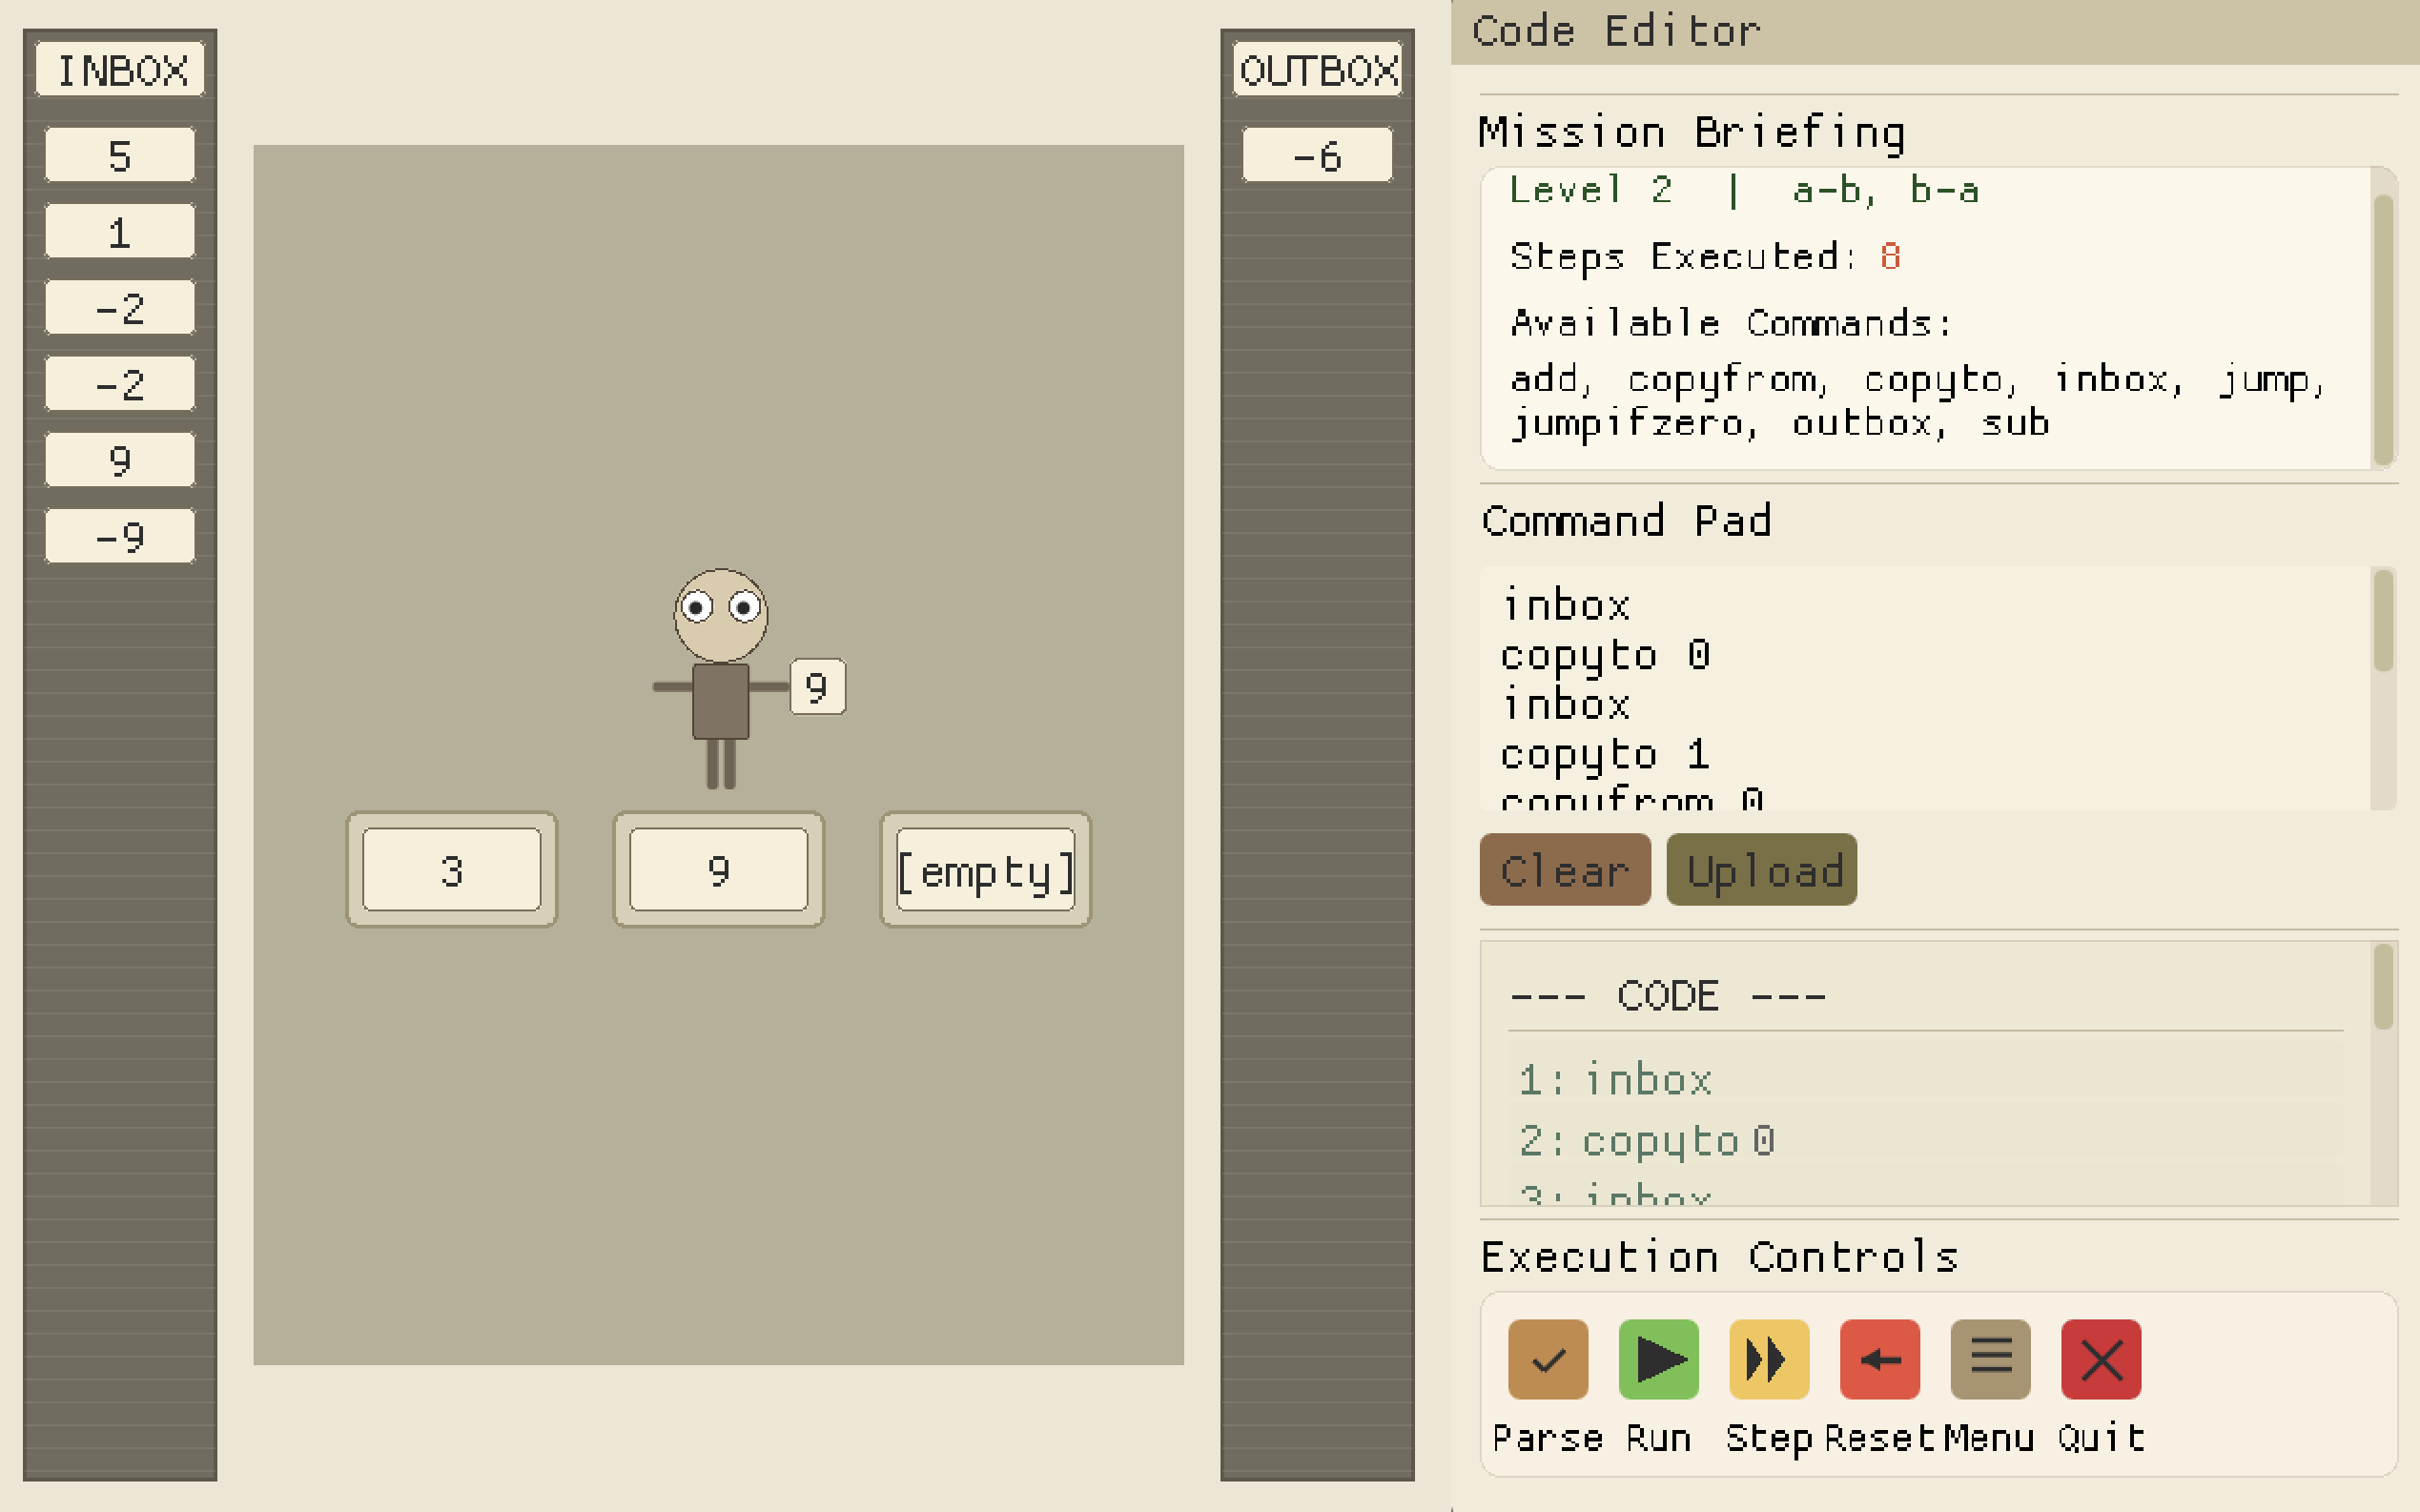
Human Resource Machine (Oct. 2025)
Developed a desktop reimagining of the puzzle game “Human Resource Machine” using C++17, SFML 3, and ImGui-SFML.
TH-MOS · Simulation & Evaluation
TH-MOS Simulation
An interactive environment connecting humanoid skills, perception, and team decisions. Unity presents the match while native MuJoCo owns the physical motion and contacts.
Experiences
MARS Lab, Tsinghua University
Research Assistant: 2025.12 - Present.
Topics: Humanoid Locomotion, Foundation Models, VLAs.
Research Advisor: Prof. Hang Zhao.
THMOS, Tsinghua University
Technical Leader: 2025.09 - Present.
Topics: Soccer-Oriented Locomotion, Multi-Robot Coordination Logic.